
EE 570: Location and Navigation: Theory & Practice
Description: EE 570: Location and Navigation: Theory Practice Navigation Mathematics Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory Practice Slide 1 of 14 Navigation Mathematics : Coordinate Frames - ECI The Earth-Centered Inertial
Related Topics
Download Presentation
"EE 570: Location and Navigation: Theory & Practice" is the property of its rightful owner. Permission is granted to download and print the materials on this website for personal, non-commercial use only, and to display it on your personal computer provided you do not modify the materials and that you retain all copyright notices contained in the materials. By downloading content from our website, you accept the terms of this agreement.
Presentation Transcript
slide1. EE 570: Location and Navigation: Theory & Practice Navigation Mathematics Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 1 of 14<br>
slide2. Navigation Mathematics : Coordinate Frames - ECI The Earth-Centered Inertial (ECI) Coordinate Frame
An Inertial coordinate frame is one that does NOT accelerate (rectilinearly) or change its orientation (wrt the “stars”)
All inertial sensors measure “inertial” motion
Gyroscopes measure rate of change of inertial orientation
Accelerometers measure inertial acceleration
The ECI frame will be referred to as the i-frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 2 of 14<br>
slide3. Navigation Mathematics : Coordinate Frames - ECI The Earth-Centered Inertial (ECI) Coordinate Frame
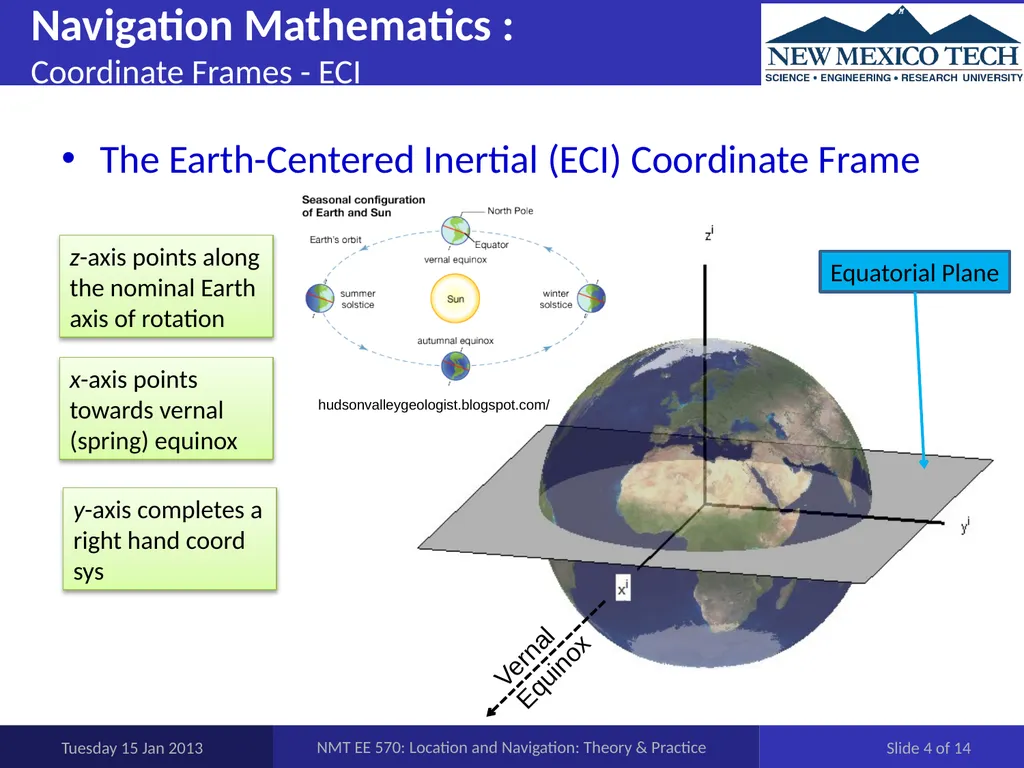
The origin of the ECI frame is located at the center of mass of the Earth
The z-axis points along the nominal axis of rotation of the earth
True North NOT magnetic North!!
The x-axis lies in the equatorial plane and points from the Earth to the Sun at the vernal equinox
Defined by the intersection of the equatorial plane and Earth-Sun orbital plane
The y-axis is simply chosen to conform to a right hand coordinate system Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 3 of 14 The ECI coordinate frame does NOT rotate with the Earth<br>
slide4. Navigation Mathematics : Coordinate Frames - ECI The Earth-Centered Inertial (ECI) Coordinate Frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 4 of 14 z-axis points along the nominal Earth axis of rotation x-axis points towards vernal (spring) equinox y-axis completes a right hand coord sys hudsonvalleygeologist.blogspot.com/<br>
slide5. Navigation Mathematics : Coordinate Frames - ECEF The Earth-Centered Earth-Fixed (ECEF) Coordinate Frame
The ECEF coordinate frame is NOT an inertial frame
The ECEF coordinate frame is fixed with respect to the Earth
The ECEF frame will be referred to as the e-frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 5 of 14 The ECEF coordinate frame is fixed with respect to the Earth<br>
slide6. Navigation Mathematics : Coordinate Frames - ECEF The Earth-Centered Earth-Fixed (ECEF) Coordinate Frame
The origin of the ECEF frame is located at the center of mass of the Earth (same as ECI)
The z-axis points along the nominal axis of rotation of the earth (same as ECI)
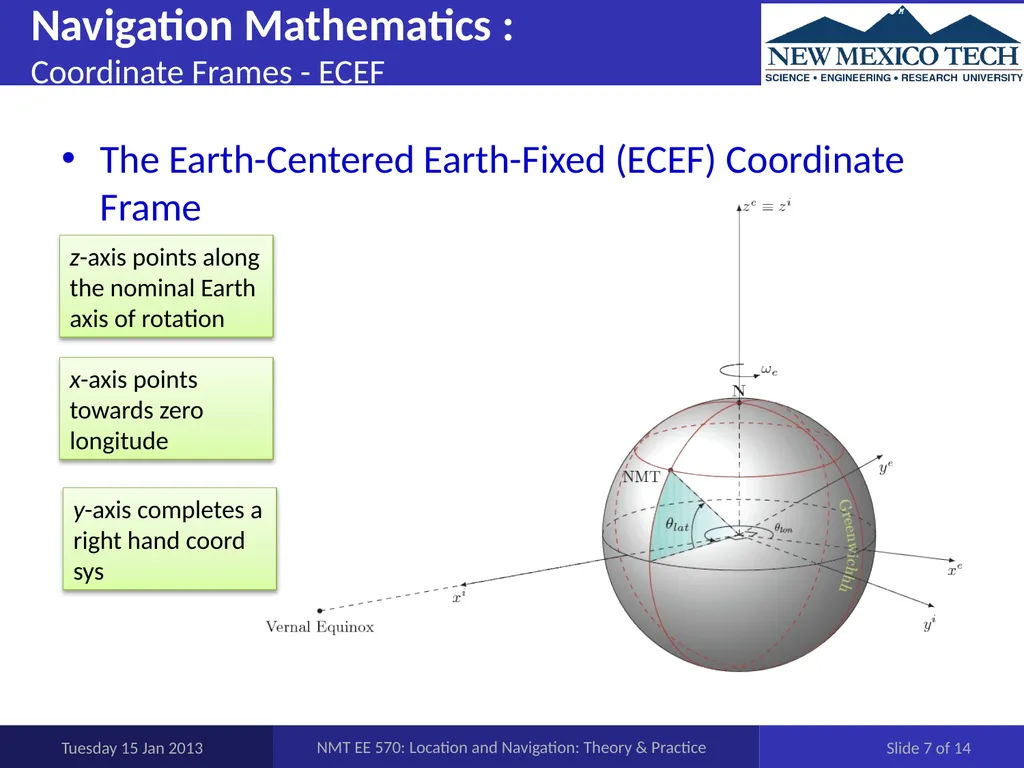
The x-axis lies at the intersection of the equatorial plane and the reference meridian plane (i.e. Greenwich meridian)
Concept of latitude and longitude
The y-axis is simply chosen to conform to a right hand coordinate system Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 6 of 14<br>
slide7. Navigation Mathematics : Coordinate Frames - ECEF The Earth-Centered Earth-Fixed (ECEF) Coordinate Frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 7 of 14 z-axis points along the nominal Earth axis of rotation x-axis points towards zero longitude y-axis completes a right hand coord sys<br>
slide8. Navigation Mathematics : Coordinate Frames - Nav The Local Navigation (Nav) Coordinate Frame
The Nav coordinate frame is typically NOT fixed with respect to the Earth
The x/y axes lie in a plane which is locally-level or tangential to the Earth’s surface
The Nav frame is sometimes called the goedetic, geographic, locally-level, or tangential frame
The Nav frame will be referred to as the n-frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 8 of 14 The Nav coordinate frame moves with the vehicle of interest<br>
slide9. Navigation Mathematics : Coordinate Frames - Nav The Local Navigation (Nav) Coordinate Frame
The origin of the Nav frame is located at the center of mass of the vehicle
The z-axis points “down” along the normal to the Earth’s surface
Approximately towards the center of the Earth
The x-axis points to the North pole
The y-axis is simply chosen to conform to a right hand coordinate system
This configuration is often referred to as a NED frame
x North, y East, z Down Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 9 of 14<br>
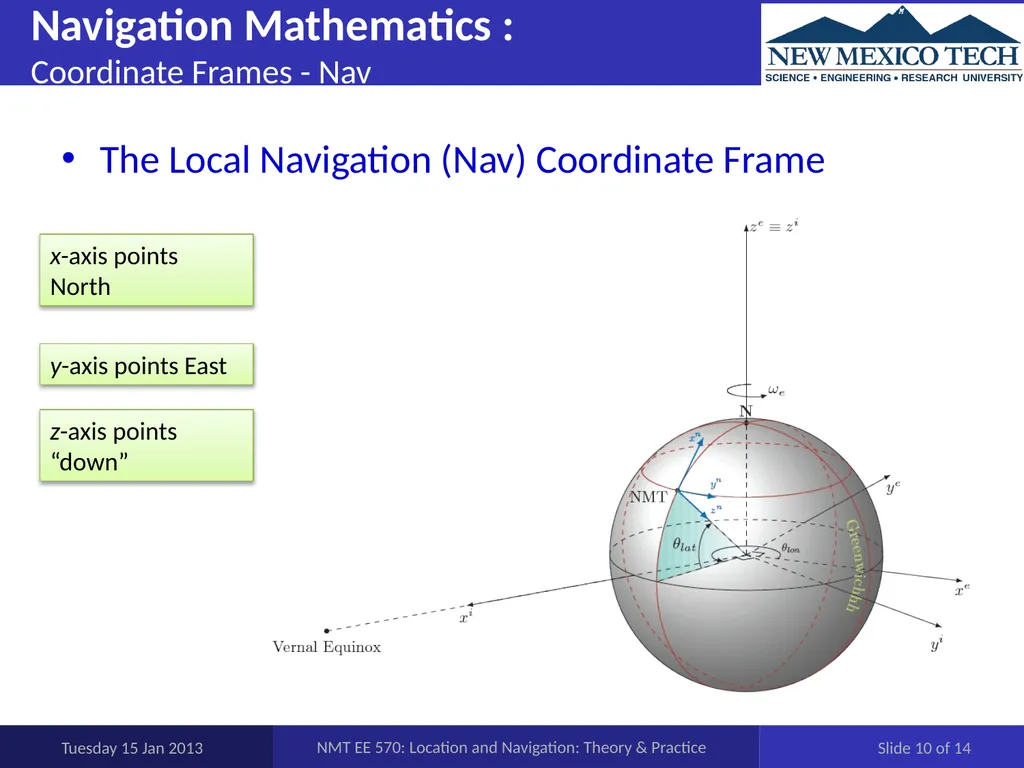
slide10. Navigation Mathematics : Coordinate Frames - Nav The Local Navigation (Nav) Coordinate Frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 10 of 14 z-axis points “down” x-axis points North y-axis points East<br>
slide11. Navigation Mathematics : Coordinate Frames - Body The Body Coordinate Frame
The body coordinate frame is fixed with respect to the vehicle
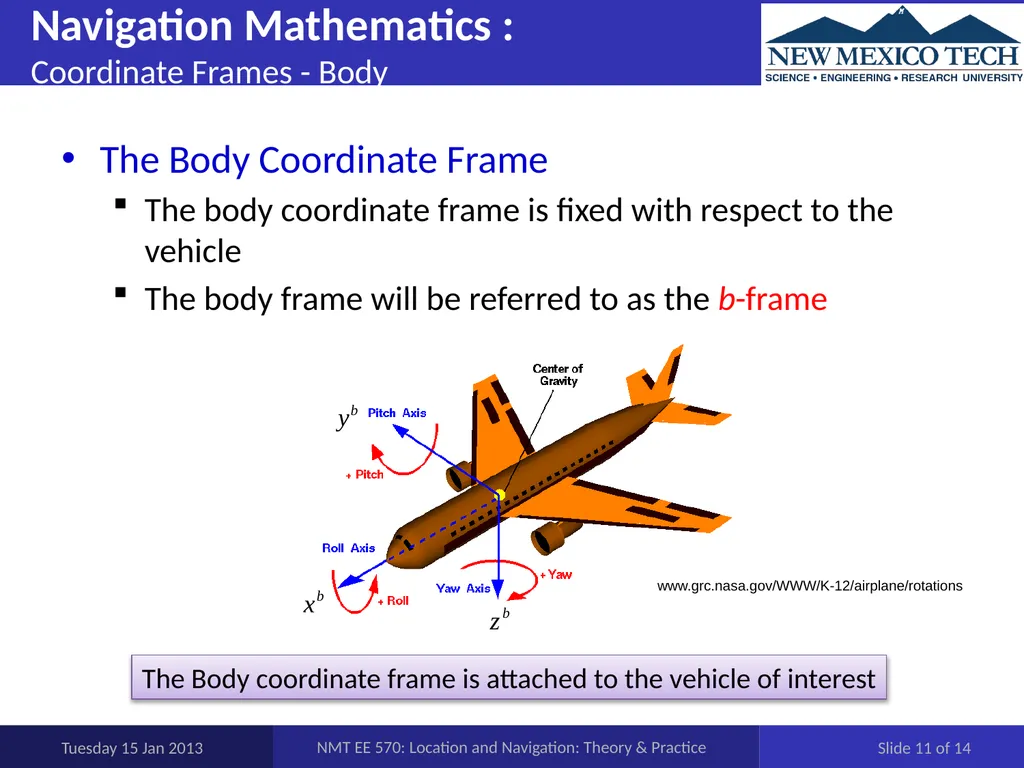
The body frame will be referred to as the b-frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 11 of 14 The Body coordinate frame is attached to the vehicle of interest www.grc.nasa.gov/WWW/K-12/airplane/rotations<br>
slide12. Navigation Mathematics : Coordinate Frames - Body The Body Coordinate Frame
The origin of the body frame is located at the center of mass of the vehicle (same as the Nav frame)
The x-axis points “forward” wrt the moving vehicle
The z-axis points loosely “down”
Changes with the roll/pitch of the vehicle
The y-axis is simply chosen to conform to a right hand coordinate system Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 12 of 14<br>
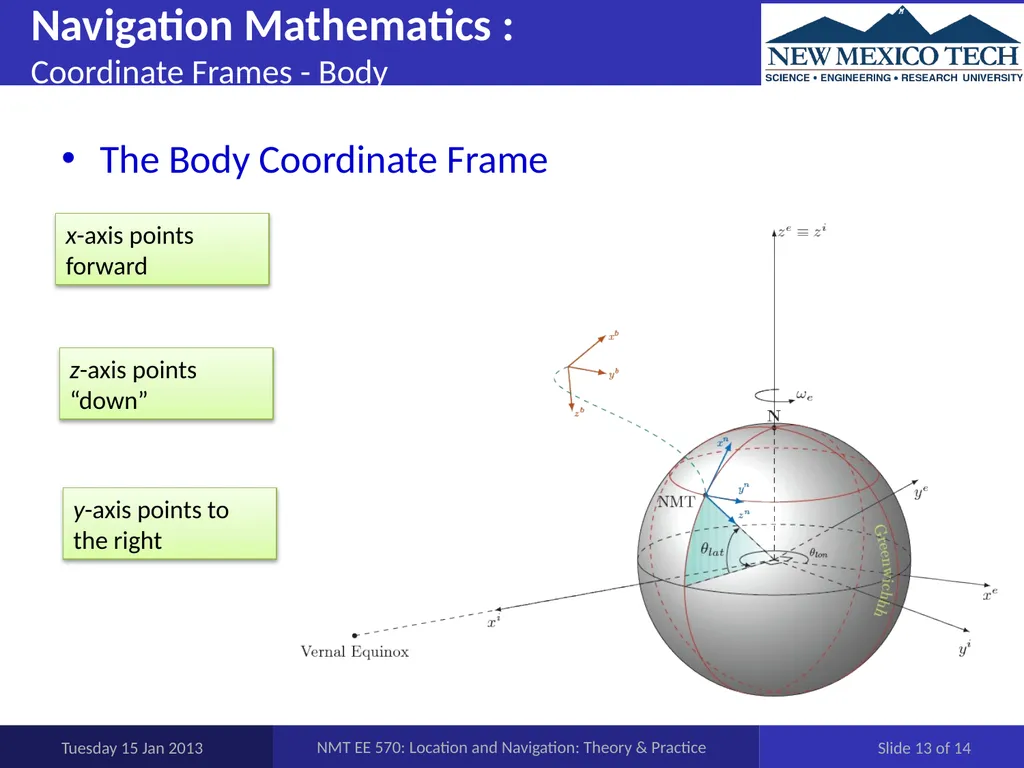
slide13. Navigation Mathematics : Coordinate Frames - Body The Body Coordinate Frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 13 of 14 z-axis points “down” x-axis points forward y-axis points to the right<br>
slide14. Navigation Mathematics : Coordinate Frames – Other Frames Other Coordinate Frames:
Wander Azimuth Frame (alternative to the Nav frame)
Does not always point North to avoid numerical stability problems near the poles
Other Locally level frames
Tangential Frame
Typically, refers to another type of ECEF frame fixed to the Earth’s surface (not moving like the n-frame)
Computer Frame
Virtual coordinate frame that represents where we think that we are Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 14 of 14<br>
slide2. Navigation Mathematics : Coordinate Frames - ECI The Earth-Centered Inertial (ECI) Coordinate Frame
An Inertial coordinate frame is one that does NOT accelerate (rectilinearly) or change its orientation (wrt the “stars”)
All inertial sensors measure “inertial” motion
Gyroscopes measure rate of change of inertial orientation
Accelerometers measure inertial acceleration
The ECI frame will be referred to as the i-frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 2 of 14<br>
slide3. Navigation Mathematics : Coordinate Frames - ECI The Earth-Centered Inertial (ECI) Coordinate Frame
The origin of the ECI frame is located at the center of mass of the Earth
The z-axis points along the nominal axis of rotation of the earth
True North NOT magnetic North!!
The x-axis lies in the equatorial plane and points from the Earth to the Sun at the vernal equinox
Defined by the intersection of the equatorial plane and Earth-Sun orbital plane
The y-axis is simply chosen to conform to a right hand coordinate system Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 3 of 14 The ECI coordinate frame does NOT rotate with the Earth<br>
slide4. Navigation Mathematics : Coordinate Frames - ECI The Earth-Centered Inertial (ECI) Coordinate Frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 4 of 14 z-axis points along the nominal Earth axis of rotation x-axis points towards vernal (spring) equinox y-axis completes a right hand coord sys hudsonvalleygeologist.blogspot.com/<br>
slide5. Navigation Mathematics : Coordinate Frames - ECEF The Earth-Centered Earth-Fixed (ECEF) Coordinate Frame
The ECEF coordinate frame is NOT an inertial frame
The ECEF coordinate frame is fixed with respect to the Earth
The ECEF frame will be referred to as the e-frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 5 of 14 The ECEF coordinate frame is fixed with respect to the Earth<br>
slide6. Navigation Mathematics : Coordinate Frames - ECEF The Earth-Centered Earth-Fixed (ECEF) Coordinate Frame
The origin of the ECEF frame is located at the center of mass of the Earth (same as ECI)
The z-axis points along the nominal axis of rotation of the earth (same as ECI)
The x-axis lies at the intersection of the equatorial plane and the reference meridian plane (i.e. Greenwich meridian)
Concept of latitude and longitude
The y-axis is simply chosen to conform to a right hand coordinate system Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 6 of 14<br>
slide7. Navigation Mathematics : Coordinate Frames - ECEF The Earth-Centered Earth-Fixed (ECEF) Coordinate Frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 7 of 14 z-axis points along the nominal Earth axis of rotation x-axis points towards zero longitude y-axis completes a right hand coord sys<br>
slide8. Navigation Mathematics : Coordinate Frames - Nav The Local Navigation (Nav) Coordinate Frame
The Nav coordinate frame is typically NOT fixed with respect to the Earth
The x/y axes lie in a plane which is locally-level or tangential to the Earth’s surface
The Nav frame is sometimes called the goedetic, geographic, locally-level, or tangential frame
The Nav frame will be referred to as the n-frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 8 of 14 The Nav coordinate frame moves with the vehicle of interest<br>
slide9. Navigation Mathematics : Coordinate Frames - Nav The Local Navigation (Nav) Coordinate Frame
The origin of the Nav frame is located at the center of mass of the vehicle
The z-axis points “down” along the normal to the Earth’s surface
Approximately towards the center of the Earth
The x-axis points to the North pole
The y-axis is simply chosen to conform to a right hand coordinate system
This configuration is often referred to as a NED frame
x North, y East, z Down Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 9 of 14<br>
slide10. Navigation Mathematics : Coordinate Frames - Nav The Local Navigation (Nav) Coordinate Frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 10 of 14 z-axis points “down” x-axis points North y-axis points East<br>
slide11. Navigation Mathematics : Coordinate Frames - Body The Body Coordinate Frame
The body coordinate frame is fixed with respect to the vehicle
The body frame will be referred to as the b-frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 11 of 14 The Body coordinate frame is attached to the vehicle of interest www.grc.nasa.gov/WWW/K-12/airplane/rotations<br>
slide12. Navigation Mathematics : Coordinate Frames - Body The Body Coordinate Frame
The origin of the body frame is located at the center of mass of the vehicle (same as the Nav frame)
The x-axis points “forward” wrt the moving vehicle
The z-axis points loosely “down”
Changes with the roll/pitch of the vehicle
The y-axis is simply chosen to conform to a right hand coordinate system Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 12 of 14<br>
slide13. Navigation Mathematics : Coordinate Frames - Body The Body Coordinate Frame Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 13 of 14 z-axis points “down” x-axis points forward y-axis points to the right<br>
slide14. Navigation Mathematics : Coordinate Frames – Other Frames Other Coordinate Frames:
Wander Azimuth Frame (alternative to the Nav frame)
Does not always point North to avoid numerical stability problems near the poles
Other Locally level frames
Tangential Frame
Typically, refers to another type of ECEF frame fixed to the Earth’s surface (not moving like the n-frame)
Computer Frame
Virtual coordinate frame that represents where we think that we are Tuesday 15 Jan 2013 NMT EE 570: Location and Navigation: Theory & Practice Slide 14 of 14<br>