Search Results for 'position robot'

position robot published presentations and documents on DocSlides.
ROBOT SENSORS AND ROBOT VISON
by marina-yarberry
T. . Bajd. and M. . Mihelj. Proprioceptive senso...
Gyro Sensor Positioning Robot DESIGN Lesson
by danika-pritchard
How Many Gyros should your robot have?. Depends o...
Course Presentation
Course Presentation
by mitsue-stanley
Outline. 1. Introduction. 2. The Bayes Filter. 3....
STANDARDS IN ROBOTICS
by trish-goza
T. . Bajd. and M. . Mihelj. Coordinate frames of...
Gaits
Gaits
by luanne-stotts
Cost of Transportation. Wheeled Mobile Robots. Mo...
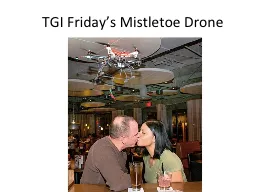
TGI Friday’s Mistletoe Drone
by debby-jeon
www.uasvision.com. /2014/12/10/mistletoe-. quadco...
Gaits
Gaits
by natalia-silvester
Cost of Transportation. Wheeled Mobile Robots. Mo...
Inverse Kinematics Kris
by natalia-silvester
Hauser. CS B659: Principles of Intelligent Robot ...
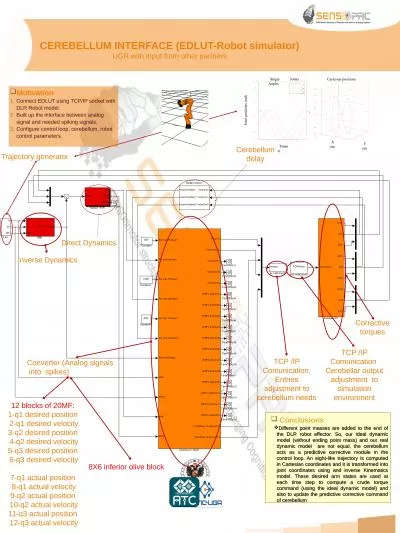
CEREBELLUM INTERFACE (EDLUT-Robot
by byrne
simulator. ). UGR . with. input . from. . other....
NAO - II 	 Major Project – SSAD
NAO - II Major Project – SSAD
by carneos
Advisor . : . Dr. . Kamalakar. . Karlapalem. Men...
The  Robotic ENT Microsurgery System (REMS): Calibration and IRB
The Robotic ENT Microsurgery System (REMS): Calibration and IRB
by ash
Study, and Tool Holder Design. Checkpoint Presenta...
Intro  to  Movement of robots and introduction to kinematics of robots
Intro to Movement of robots and introduction to kinematics of robots
by alida-meadow
Kinematics: . constraints on getting around the ...
Control 3 Motion Control (kinematic control)
by lindy-dunigan
for mobile platform. The objective of a kinematic...
Introduction to Robotics
by test
Robot.  ”programmable, multifunction, manipula...
Mapping and Localization with RFID Technology
by tatiana-dople
Matthai Philipose, Kenneth P Fishkin, . Dieter Fo...
Automation with RobotC
by liane-varnes
Starting to write and troubleshoot . computer cod...
Visibility Graph
Visibility Graph
by liane-varnes
Voronoi. Diagram. Control is easy: stay equidist...
Locomotion: Chapter 1
by conchita-marotz
Enabling robots to move. Many bio-inspired method...
Kinematics
Kinematics
by lindy-dunigan
u. sing slides from D. . Lu. Goals of this class....
Communication
Communication
by yoshiko-marsland
Piazza. Code. Email: Angel. Computers in Lab. Joi...
Locomotion: Chapter 1
by faustina-dinatale
Enabling robots to move. Many bio-inspired method...
Hand Posture Subspaces for Dexterous Robotic Grasping
by kittie-lecroy
Dipartimento. . di. . Ingegneria. . dell’Inf...
Mobile Robot Localization and Mapping with Uncertainty usin
by pamella-moone
Paper – Stephen Se, David Lowe, Jim Little. Pre...
Abstract ID 15624    Title Assessment of Patient Setup Accuracy at a
Abstract ID 15624 Title Assessment of Patient Setup Accuracy at a
by teresa
ed at Another Location Using Robotic Positioner a...
Introduction to Computer Science – Chapter 5
by min-jolicoeur
CSc. 2010. Spring 2011. Marco Valero. Overview. ...
Introduction to Computer Science – Chapter 5
by tatyana-admore
CSc. 2010. Spring 2011. Marco Valero. Overview. ...
Learning Agile and Dynamic Motor Skills for Legged Robots
by KissableLips
Jemin. . Hwangbo. , . Joonho. Lee, Alexey . Doso...
Robotics Programming with
by beatever
Java in MATLAB. [CON 3694]. JavaOne. 2015. Floria...
HOMOGENOUS TRANSFORMATION
by bobradio
MATRICES. T. . Bajd. and M. . Mihelj. The homogen...
Autonomous Navigation for Flying Robots
by dsuser1
Lecture 2.3:. 2D Robot Example. JĂĽrgen . Sturm. T...
Human Interaction Development Using the Countess Quanta Robot
by danika-pritchard
Brad Pitney. Yin Shi. Development Overview. Robot...
Simultaneous  Localization and Mapping
Simultaneous Localization and Mapping
by lois-ondreau
Matthew Thompson, UF. matthewbot@ufl.edu. Prolifi...
4/10/2018 IENG 475: Computer-Controlled Manufacturing Systems
by kittie-lecroy
1. IENG 475 - Lecture 15. Robot Programming in AC...
Deep sensing with wearable devices
by test
Valentin Radu. 26 May 2016, 3DT. 3DT. Data Scienc...
Color Sensor Positioning and Shielding
by alida-meadow
Robot DESIGN Lesson. WHERE SHOULD THE COLOR SENSO...
Autonomous Navigation of a
by karlyn-bohler
Humanoid Robot over Unknown Rough Terrain using a...
RGB,
RGB,
by sherrill-nordquist
HSL, . HSV. HSL, HSV: easier to define, closer to...
FTC Software Intro (
by myesha-ticknor
Robotc. ). Team 5220 . Roboknights. Team 5220 Rob...
Basic Turning
Basic Turning
by lois-ondreau
BEGINNER PROGRAMMING LESSON. Lesson Objectives. L...
Planning With
Planning With
by pasty-toler
Uncertainty for UAVs. Sameer. . Ansari. Billy Ga...